| Spesification | |||
|---|---|---|---|
| Robot variant | PoWa 16 | PoWa 20 | PoWa 30 |
| Robot version | CRB1920 ?16/1.96 | CRB1920 ? 20/1.67 | CRB1920 ? 30/1.35 |
| Reach (m) | 1.96 m (wrist) 2.1 m (flange) |
1.67 m (wrist) 1.82 m (flan) |
WCP 1.35 m (wrist) 1.52 m (flange) |
| Payload (kg) | up to 17 kg* | up to 22 kg* | up to 32 kg* |
| Rated payload (kg) | 16 kg | 20 kg | 30 kg |
| Number of axes | 6 | ||
| Protection | IP67 | ||
| ISO 14644-1 Cleanroom | ISO 4 | ||
| Mounting | Any angle, including Floor/Wall/Ceiling | ||
| Customer Power on flange | C1+C2: 24V, 1.5A per pin pair, integrated power, 4A total with OmniCore E10, 5.5A total with OmniCore C30 |
||
| Customer Signal on flange | C1: integrated 8DI/6DO/4AI C2: integrated 100Mbit/s Ethernet |
||
| *wrist down configuration | |||
| Specifications | |||
| Communication on flange | C1: Modbus RTU, RS485 C2: Modbus TCP, TCP/IP |
||
| Tool flange inteface | ISO 9409-1-50-6-M6 | ||
| Arm load | 10kg on axis 3 or lower arm | ||
| Controller | OmniCore E10, OmniCore C30, OmniCore 90XT** | ||
| Floor cable(m) | 2m / 5m | ||
| Safety | ISO 10218-1:2025, ISO 13849-1:2023 PL d Cat 3 | ||
| Noise | <65 dB(A) | ||
| Working temperature | +5?C to +45?C | ||
| Storage temperature | ?25?C to 55?C | ||
| Humidity | <95% at constant temperature (not intended to operate with condensation) | ||
| Performance(400-900-400, pick-place cycle) | |||
| Cycle Time(with E10 Type A) | 1.92s with rated payload, 1.71s with 1kg payload |
2.00s with rated payload, 1.77s with 1kg payload |
2.44s with rated payload, 1.96s with 1kg payload |
| Cycle Time(with C30 Type B) | 1.87s with rated payload, 1.65s with 1kg payload |
1.92s with rated payload, 1.67s with 1kg payload |
2.36s with rated payload, 1.80s with 1kg payload |
| Performance (according to ISO 9283) | |||
| Pose repeatability, RP | 0.03 mm | 0.03 mm | 0.03 mm |
| Path repeatability, RT | 0.1 mm | 0.1 mm | 0.1 mm |
| Max TCP speed @rated payload with E10 | 5.2 m/s | 5.1 m/s | 3.9 m/s |
| Max TCP speed@1kg payload with E10 | 7.0 m/s | 7.0 m/s | 6.0 m/s |
| Max TCP speed @rated payload with C30 | 5.2 m/s | 5.2 m/s | 3.9 m/s |
| Max TCP speed@1kg payload with C30 | 7.0 m/s | 7.2 m/s | 6.0 m/s |
| Physical and movement | |||
| Robot Base | 225*225 mm | ||
| Robot weight (kg) | 63 kg | 63 kg | 61 kg |
| Working range | |||
| Axis 1 (rotation) | +/- 360? | ||
| Axis 2 (arm) | +/- 180? | ||
| Axis 3 (arm) | +80/- 248? | +78/- 249? | +74/- 243? |
| Axis 4 (wrist) | +/- 360? | ||
| Axis 5 (bend) | +/- 180? +/- 270? (which could be changed by customers) |
||
| Axis 6 (turn) | +/- 400? | ||
| Axis max. speed | |||
| Axis 1 (rotation) | 149?/s | 149?/s | 149?/s |
| Axis 2 (arm) | 149?/s | 149?/s | 149?/s |
| Axis 3 (arm) | 230?/s | 230?/s | 230?/s |
| Axis 4 (wrist) | 283?/s | 300?/s | 300?/s |
| Axis 5 (bend) | 300?/s | 300?/s | 300?/s |
| Axis 6 (turn) | 300?/s | 300?/s | 300?/s |
| Omnicore E10 controller / Omnicore C30 controller | |||
| Controller type | Omnicore E10 controller | Omnicore C30 controller | |
| Dimensions ( W x D x H) | 449?338?89 mm | 440x133x340 | |
| Weight | 12 kg | 25kg | |
| IP level | IP20 | IP20 | |
| Available Communication Fieldbuses | PROFINET Controller, PROFINET Device, PROFIsafe Controller, PROFIsafe Device, CC-Link IE MASTER, CC- Link IE Device, CC ? Link Safety Master**, CC ? Link Safety Device**, EtherCAT device, EtherCAT Master**, EtherCAT FSoE device, EtherCAT FSoE Master**, Ethernet/IP Adapter, Ethernet/IP Scanner, CIP Safety Adapter, CIP Safety Scanner** ** Coming soon |
PROFINET Controller , PROFINET Device , EtherNet/IP Scanner , EtherNet/IP Adapter, CC-Link IE FB Master , CC-Link IE FB Device, EtherCAT Device , EtherCAT Master, PROFlenergy, DeviceNet Single ch. PROFIsafe Controller, PROFIsafe Device, CIP Safety Adapter, EtherCAT FSoE Device | |
| Interface | Built in16DI/8DO | Built in 16I 16O | |
| Cable length to Flexpendant | 3m/10m | ||
| Flexpendant | |||
| Screen | 8?? color touch screen | ||
| Resolution | 1024×768 | ||
| Protection | IP67 | ||
| Weight | 1.2kg | ||
| Available Cable length | 3m/10m | ||
| Additional features | 3D Joystick Adaptable for left-handed users | ||
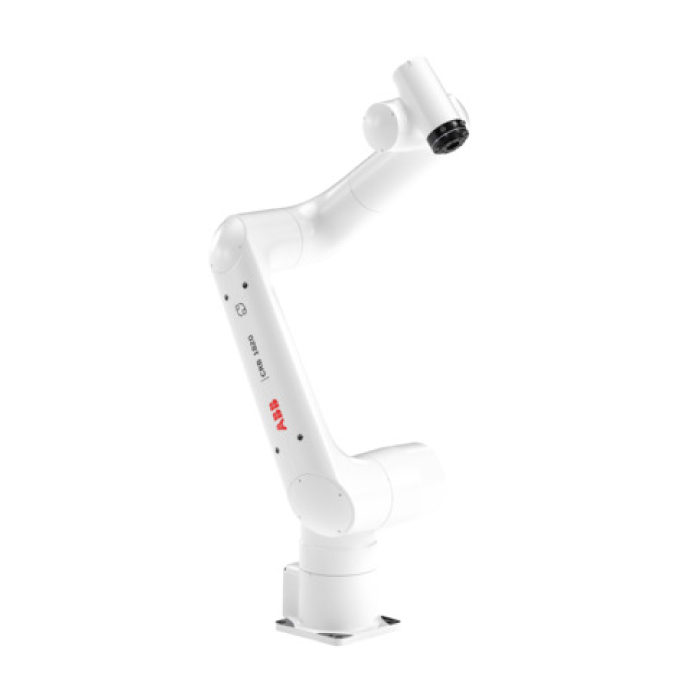
PoWa-(CRB-1910-CRB-1920)
High speed cobot family built for industrial performanc
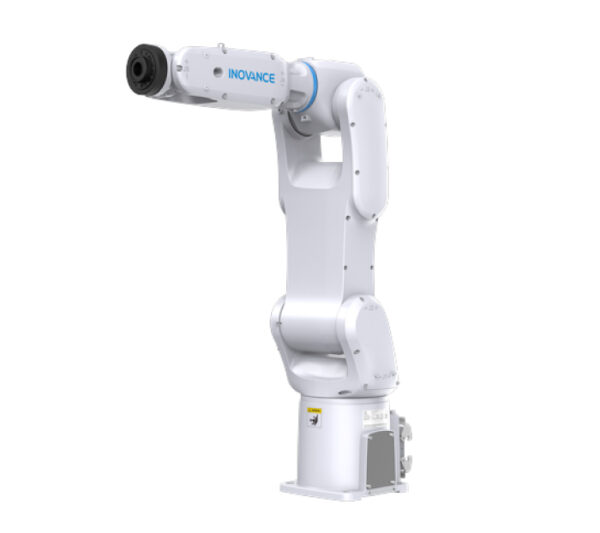
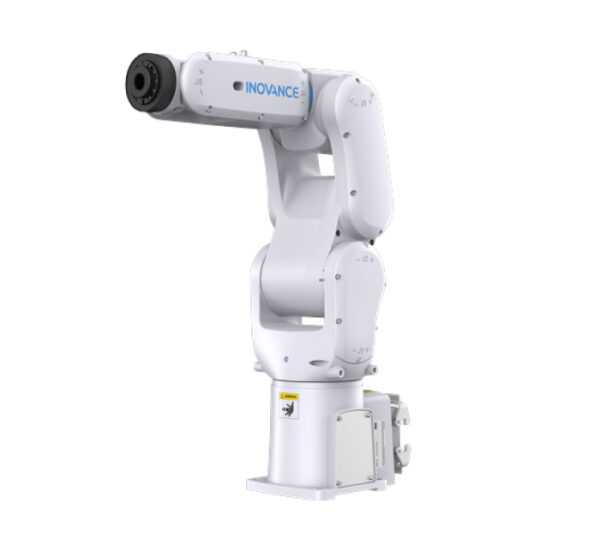
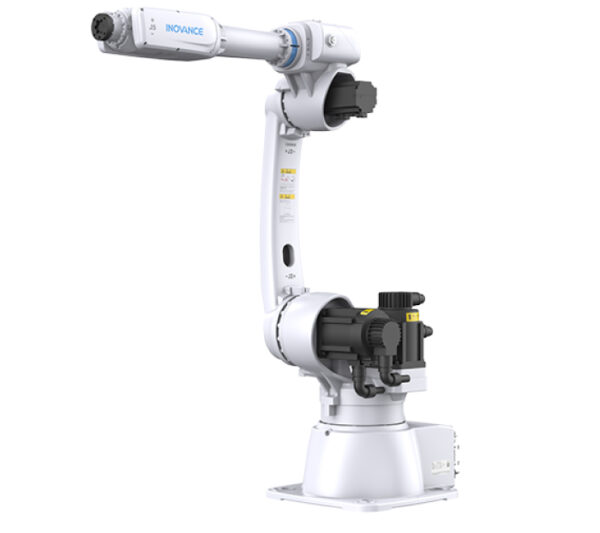
A name that symbolizes powerful performance, PoWa brings industrial grade performance to collaborative automation without compromising on safety or ease of use. With speeds exceeding 5m/s with rated payload, PoWa sets a new benchmark for high speed collaborative robots.
PoWa combines the compact, lightweight design of a cobot with exceptional speed, enabling manufacturers to automate demanding and productivity-driven industrial applications including machine tending, material handling, palletizing, welding and screwdriving.
ilt for fast deployment, PoWa can be up and running in as little as 60 minutes*, supported by no code programming and plug and play setup. Its fenceless operation and collaborative safety features allow PoWa to work efficiently alongside people in space constrained or brownfield environments.
Family of powerful robots
The PoWa portfolio spans payloads from 7 kg up to 30 kg, offering a scalable solution for a wide range of industrial applications all within one powerful cobot family.