| Spesification | |
|---|---|
| Structural Style | Vertical multi-axis cascading structure |
| Number of axes | 6 axes |
| Maximum reach | 1422 mm |
| Repeatability | ?0.05mm |
| Maximum wrist load | 10 kg |
| IP rating | IP65 for the body, IP67 for the wrist |
| Maximum speed : | |
| J1 axis | 200?/s |
| J2 axis | 200?/s |
| J3 axis | 200?/s |
| J4 axis | 375?/s |
| J5 axis | 375?/s |
| J6 axis | 600?/s |
| Maximum motion range : | |
| J1 axis | -170? to +170? |
| J2 axis | -160? to +60? |
| J3 axis | -80? to +160? |
| J4 axis | -180? to +180? |
| J5 axis | -140? to +140? |
| J6 axis | -360? to +360? |
| Allowed wrist load torque : | |
| J4 axis | 22 N?m |
| J5 axis | 22 N?m |
| J6 axis | 9.8 N?m |
| Allowed wrist load inertia : | |
| J4 axis | 0.63 kg?m? |
| J5 axis | 0.63 kg?m? |
| J6 axis | 0.2 kg?m? |
| User interface : | |
| Wiring | 18 signal channels, 30 V/0.5 A |
| Air circuit | Air hose: ?8 mm x 1 Withstanding pressure: 0.59 Mpa |
| Ambient condition : | |
| Ambient temperature | 0?C to 45?C |
| Ambient humidity (RH) | 5% RH to 95% RH, non-condensing |
| Maximum temperature gradient | 1.5?C/min |
| Weight | 130 kg |
| Input power (average power consumption) | 3 kVA (0.6 kW) |
| Matching controller | IRCB501-6ND-INT |
| Mounting method | Floor-standing installation |
| Noise level | LAeq?80dB(A) |
| Robot base mounting area | 290 mm x 280 mm (4 x ?18 mm) |
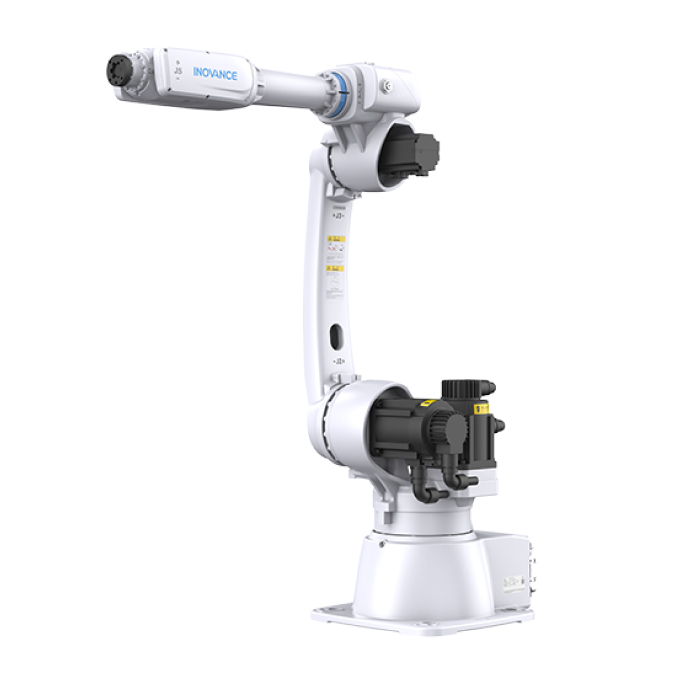
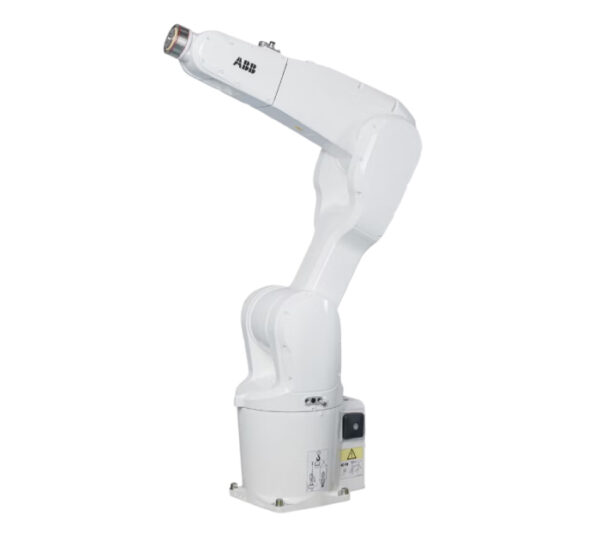
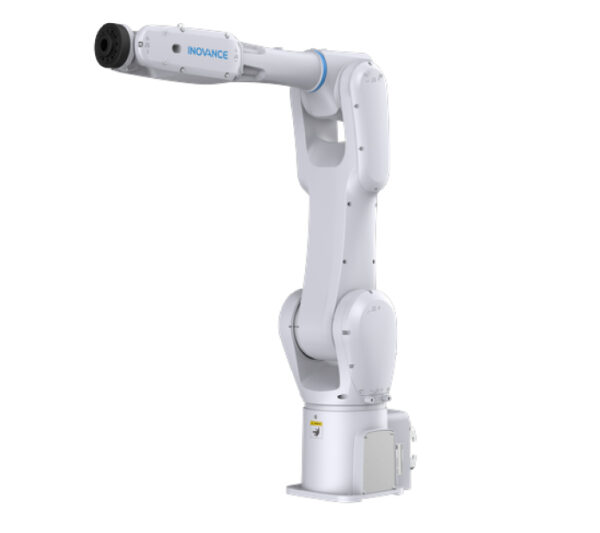
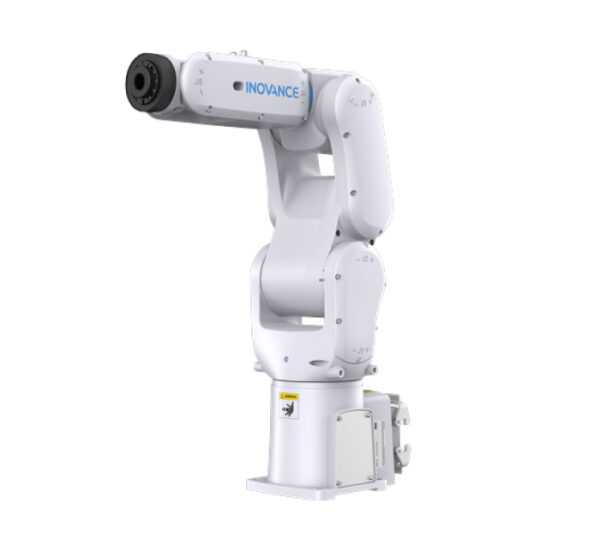
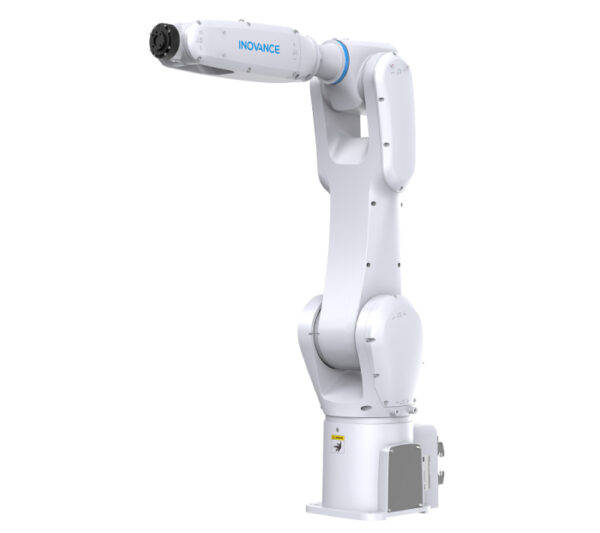
IR-R10-140S-INT
The IR-R10 series 6-axis robots offer a maximum reach of 1,422 mm and a maximum payload capacity of 10 kg. These robots provide excellent flexibility, repeatability, and speed in a compact and lightweight structure. The robots excel in usability and reliability when working with the high-protection IRCB501 series control system. With specialized motors and controllers, these robots offer cost-effective solutions for a range of scenarios including handling, loading & unloading, glue application, deburring, grinding & polishing, and welding.