| Spesification | |||
|---|---|---|---|
| Robot version | Reach (m) | Payload (kg) | Armload (kg) |
| IRB 1200-7/0.7 | 0.7 | 7 | 0.3 |
| IRB 1200-5/0.9 | 0.9 | 5 | 0.3 |
| Number of axes | 6 | ||
| Protection | Wipe down, wash down with cover Ax6 P69K, max. 30bar waterpressure, max. 80?C temperature. | ||
| Mounting | Any angle | ||
| Controller | OmniCore IRC5 Compact/IRC5 Single Cabinet | ||
| Integrated signal and power supply | 10 signals on wrist | ||
| Integrated air supply | 4 air on wrist (5 Bar) | ||
| Integrated ethernet | One 100/10 Base-TX ethernet port | ||
| Performance (according to ISO 9283) | |||
| IRB 1200-7/0.7 | IRB 1200-5/0.9 | ||
| 1 kg picking cycle 25 x 300 x 25 mm |
0.41s? | 0.42s? | |
| Max. TCP Acceleration | 35 m/s*s | 36 m/s*s | |
| Acceleration time 0-1 m/s | 0.06 s | 0.06 s | |
| Position repeatability | 0.02 mm | 0.025 mm | |
| ?based on OmniCore C30 and E10 | |||
| Electrical Connections | |||
| Supply voltage | 200-600 V, 50-60 Hz | ||
| Rated power transformer rating | 4.5 kVA | ||
| Power consumption | 0.39 kW | ||
| Physical | |||
| Robot base | 210 x 210 mm | ||
| Robot height | |||
| IRB 1200-7/0.7 | 869 mm | ||
| IRB 1200-5/0.9 | 967 mm | ||
| Robot weight | |||
| IRB 1200-7/0.7 | 52 kg | ||
| IRB 1200-5/0.9 | 54 kg | ||
| Environment | |||
| Ambient temperature for robot manipulator | |||
| Hygienic during operation | + 5?C (41?F) to + 35?C (95?F)If > 35?C (95?F), pls conact ABB | ||
| Complete robot during transportation and storage |
– 25?C (-13?F) to + 55?C (131?F) | ||
| During short periods (max. 24 hours) | up to + 70?C (158?F) | ||
| Relative humidity | Max. 95% | ||
| Noise level | < 70 dB | ||
| Data and dimensions may be changed without notice. | |||
| Movement | |||
| Axis movement | Working range | Axis max. speed | |
| Axis 1 rotation | +170? to -170? | 280? | |
| Axis 2 arm | +135? to -100?? | 230? | |
| Axis 3 arm | +70? to -200? | 290? | |
| Axis 4 wrist | +270? to -270? | 380? | |
| Axis 5 bend | +128? to -128? | 380? | |
| Axis 6 turn | Default: +400? to -400? Max. rev: ?242 | 600? | |
| ?Axis 2 for IRB 1200-5/0.9 is +130? to -100? | |||
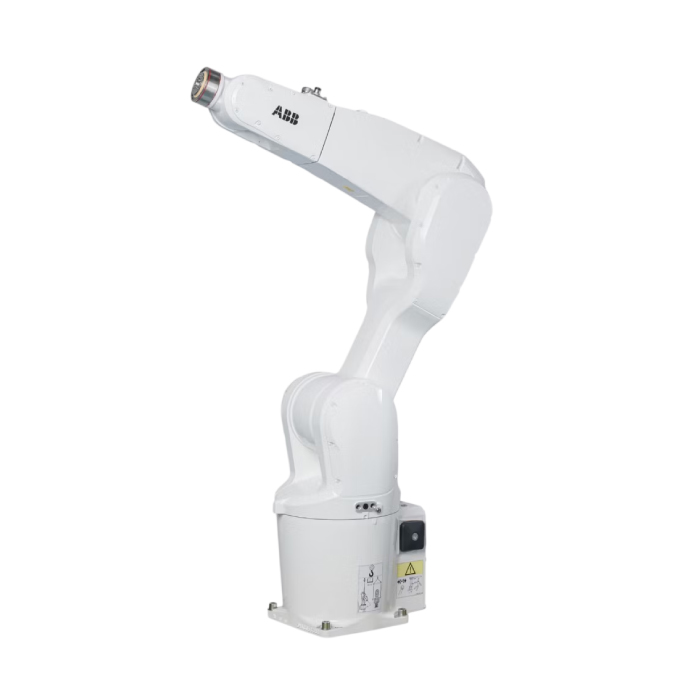
IRB 1200 Hygienic
Two types of cleaning
The IRB 1200 Hygienic robot offers two types of cleaning: wipe down cleaning for use in low care food packaging environments and wash down cleaning, where the is fitted with a protection cover, for use in high care food processing and packing environments.
For the Food & Beverage sector these new hygienic features promote food safety for primary packaging and hygienic food processing of products such as meat, poultry, fish, and fruits produce and for the Food Service sector the new hygienic features promote food safety in food handling and assembly applications for quick service restaurants, kiosks and high-volume central kitchens.