| Spesification | |||||
|---|---|---|---|---|---|
| Robot version | Diameter | Payload (g) | No. Axes | ||
| IRB 360-1/1130* | 1 kg | 1130 mm | 3/4 | ||
| IRB 360-3/1130 | 3 kg | 1130 mm | 3/4 | ||
| IRB 360-1/1600 | 1 kg | 1600 mm | 4 | ||
| IRB 360-6/1600 | 6 kg | 1600 mm | 4 | ||
| IRB 360-8/1130 | 8 kg | 1130 mm | 4 | ||
| Supplementary load | on upper arm | 350 g | |||
| on lower arm | 350 g | ||||
| Integrated signal supply | 12 poles 50V, 250mA | ||||
| Integrated vacuum supply | Max. 7 bar/max vacuum 0.75 bar | ||||
| * Tested by IPA, all axes | |||||
| Physical | |||||
| Robot mounting | Inverted | ||||
| Weight | 120 kg (Standard & wash down) | ||||
| 145 kg (Stainless wash down) | |||||
| Performance | |||||
| Position repeatability | 0.1 mm | ||||
| Angular repeatability | Standard & stainless axis 4 | 0.4? | |||
| Wash-down axis 4 | 1.5? | ||||
| Cycle times | |||||
| 0.1 kg | 1 kg | 3 kg | 6 kg | 8 kg | |
| 25/305/25 (mm)+A29:F29 | |||||
| IRB 360-1/1130 | 0.30 | 0.36 | |||
| IRB 360-3/1130 | 0.40 | 0.40 | 0.52 | ||
| IRB 360-8/1130 | 0.38 | 0.42 | 0.60 | ||
| IRB 360-1/1600 | 0.35 | 0.40 | |||
| IRB 360-6/1600 | 0.43 | 0.48 | 0.60 | ||
| 90/400/90 (mm) | |||||
| IRB 360-1/1130 | 0.44 | 0.51 | |||
| IRB 360-3/1130 | 0.60 | 0.60 | 0.75 | ||
| IRB 360-8/1130 | 0.55 | 0.65 | 0.92 | ||
| IRB 360-1/1600 | 0.50 | 0.54 | |||
| IRB 360-6/1600 | 0.57 | 0.63 | 0.80 | ||
| The cycle times are measured under real conditions, but may vary depending on the actual application. Please use RobotStudio or real cycle tests to verify actual cycle time. | |||||
| Electrical connections | |||||
| Supply voltage | 200-600 V, 60 Hz | ||||
| Transformer rating | 7.2 kVA | ||||
| Power consumption | type of movement | IRB 360/1 | |||
| typical pick & place cycle (1 kg) | 0.477 kW | ||||
| Conveyor tracking | |||||
| speed (mm/s) | repeatability | ||||
| Constant conveyor | 200 | 1.0 mm | |||
| 350-750 | 1.5 mm | ||||
| 800-1400 | 5.0 mm | ||||
| Start/stop conveyor | 500 (start/stop in 0.2 sec) | 3.5 mm | |||
| Indexing conveyor control | 3.5 g acceleration/deceleration | 2.0 mm | |||
| The tracking is measured under real conditions with IRB 360-1/1130 & PickMaster. The figures may vary depending on the actual robot max. speed & acceleration in relation to the application demands. | |||||
| Environment | |||||
| Ambient temperature | IRB 360 manipulator | ?0?C to +45?C | |||
| Relative humidity | Max. 95 % | ||||
| Noise level | < 70 dB(A) | ||||
| Safety | Double circuits with supervision, emergency stops & safety functions, 3 position enabling device | ||||
| Emission | EMC/EMI shielded | ||||
| Clean room options axis 4 | Standard | Clean room 7 | |||
| Wash down | Clean room 5* | ||||
| Stainless | Clean room 5* | ||||
| Option | Collision detection | ||||
| * Certified by IPA Data and dimensions may be changed without notice |
|||||
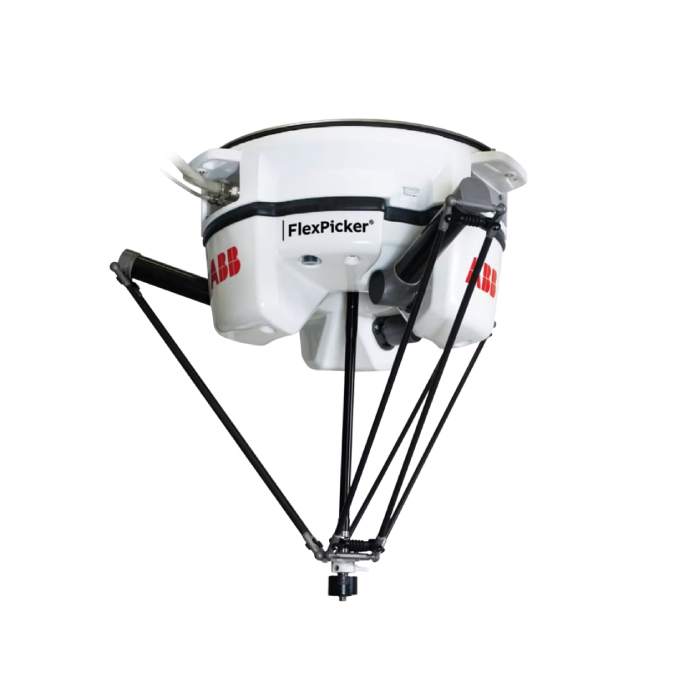
IRB-360
Fastest industrial delta robot in the world
For more than 20 years, ABB?s FlexPicker has been the leader in state-of-the-art high-speed robotic picking and packing technology. IRB 360 is the fastest industrial delta robot in the world while offering high reliability and accuracy.
ABB?s IRB 360 FlexPicker is capable of the fastest picking applications and have been optimized for packing applications. The robot has outstanding motion performance with the shortest cycle times, precision accuracy for payloads from 1 to 8kg.
The IRB 360 family includes variants with payloads of 1 kg, 3 kg, 6 kg, and 8 kg and reaches of 1130 mm and 1600 mm – meaning there is an IRB 360 for almost every need.
Featuring outstanding motion control, short cycle times, and precision accuracy, the IRB 360 can operate at very high speed in anything from narrow to wide spaces with very tight tolerances. IRB 360 is equipped with a standard tool flange for mounting larger size adjustable grippers, allowing for efficient handling of flow wrapped products at high speeds from an indexing belt.