| Spesification | |
|---|---|
| Reach | |
| Arm 1+Arm 2 | 1000 mm |
| Arm 1 | 550 mm |
| Arm 2 | 450 mm |
| Maximum speed | |
| J1+J2 | 9400 mm/s |
| J3 | 2100 mm/s |
| J4 | 705?/s |
| Repeat accuracy | |
| J1+J2 | ?0.05 mm |
| J3 | ?0.01 mm |
| J4 | ?0.01? |
| Payload (load capacity) | |
| Nominal | 10 kg |
| Maximum | 25 kg |
| Allowable load inertia of J4 | |
| Nominal | 0.5 kg?m? |
| Allowable load inertia of J5 | |
| Maximum | 1.2 kg?m? |
| Mounting hole | 200 mm ? 200 mm (4 ? ?16 mm) |
| Body weight (excluding cables) | 72.5 kg |
| Press-in force of J3 | 250 N |
| User wiring | |
| Wiring | 25x signal, 30 V, 0.5 A |
| Network port | CAT5E |
| User air circuit | Air tube: ?6 mm ? 2, ?8 mm ? 2; Pressure resistance: 0.59 Mpa |
| Ambient conditions | |
| Ambient temperature | 5?C to 40?C |
| Ambient humidity | 10% to 80% |
| Noise level | LAeq ? 80 dB(A) |
| Maximum motion range | |
| J1 | ?139? |
| J2 | ?151? |
| J3 | 420 mm |
| J4 | ?360? |
| Cycle time | 0.33s |
| Input power (average power consumption) | 2 kVA (0.3 kW) |
| Applicable control cabinet (standard) | IRCB501-4ED-INT |
| Installation method | Tabletop |
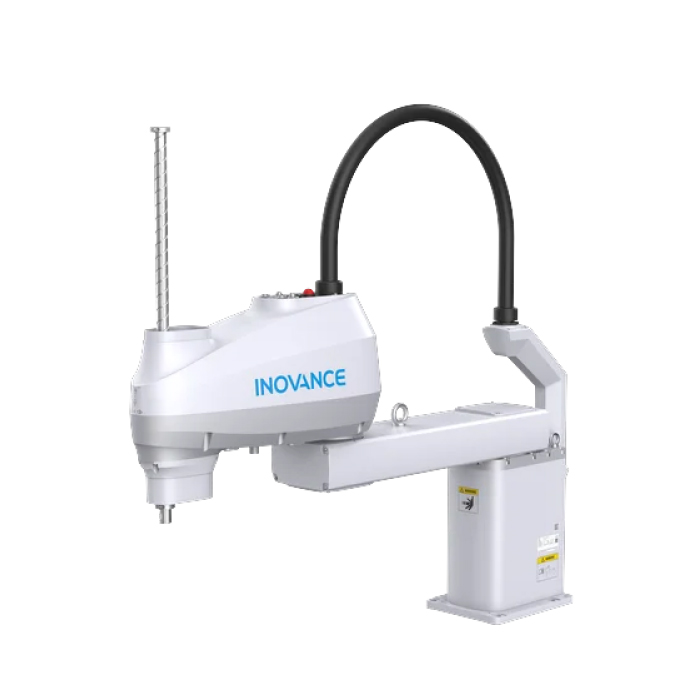
IR-S25-100Z42S-INT
The IR-S25 series robot features a maximum payload of 25 kg and a Z-axis stroke of 420 mm (360 mm for cleanroom model). The J4 axis of the robot is driven by a harmonic reducer to enhance the rigidity of Z-axis in the overturning direction when moving under the operating conditions involving high payload, long stroke and large eccentric loads. The robot offers high inertia, strong rigidity and high precision.