| Spesification | |||
|---|---|---|---|
| Robot version | Reach (m) | Handling capacity (kg) | |
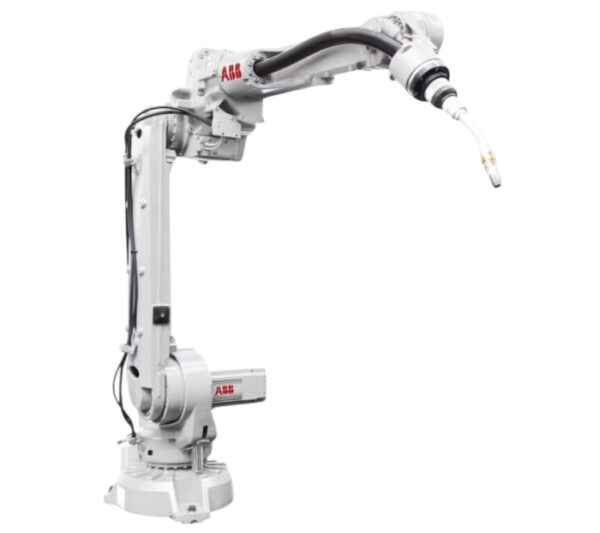
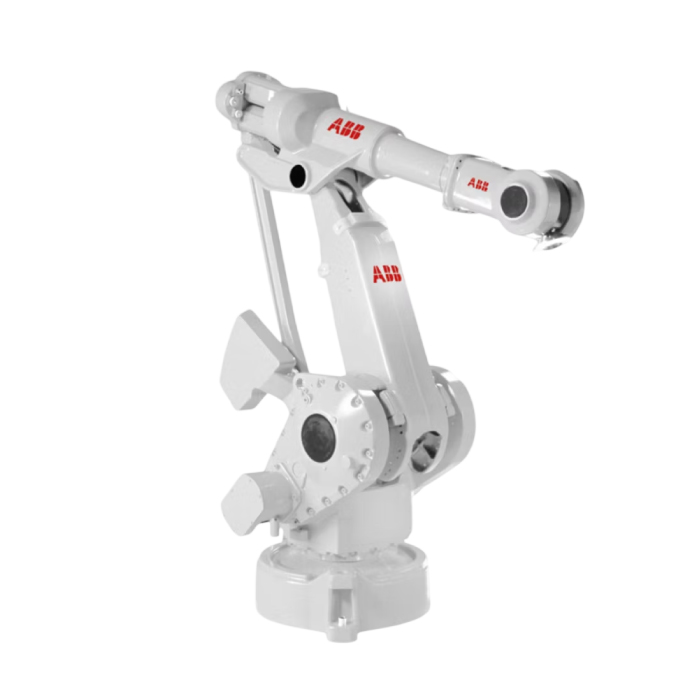
| IRB 4400/60 | 1.96 | 60 | |
| IRB 4400/L10 | 2.53 | 10 | |
| Supplementary load | |||
| on axis 2 | 35 kg | ||
| on axis 3 | 15 kg | ||
| on axis 4 | 0-5 kg | ||
| Number of axes | 6 | ||
| Protection | Standard version IP 54, Foundry Plus 2 IP 67 and high pressure steam washable | ||
| Mounting | Floor | ||
| Controller | OmniCore V250XT, V400XT | ||
| Integrated signal supply | 23 signals and 10 power on upper arm | ||
| Integrated air supply | Max. 8 bar on upper arm | ||
| Performance (according to ISO 9283) | |||
| Robot version | Position repeatability | Path repeatability | |
| IRB 4400/60 | 0.06 mm | 0.09 mm | |
| IRB 4400/L10 | 0.05 mm | 0.16 mm | |
| Electrical Connections | |||
| Supply voltage | 200-600 V, 50-60 Hz | ||
| Rated power transformer rating | 7.8 kVA | ||
| Physical | |||
| Robot base | 920 x 640 mm | ||
| Robot weight | 1040 kg | ||
| Environment | |||
| Ambient temperature for mechanical unit | |||
| During operation | +5? C (41? F) to + 45?C (113?F) | ||
| Relative humidity | Max. 95% | ||
| Noise level | Max. 70 dB (A) | ||
| Safety | Double circuits with supervision, emergency stops and safety functions, 3-position enable device | ||
| Emission | EMC/EMI shielded | ||
| Data and dimensions may be changed without notice. | |||
| Movement | |||
| Axis movement | Working range | Axis max speed IRB 4400/60 |
Axis max speed IRB 4400/L10 |
| Axis 1 rotation | +165? to -165? | 150?/s | 150?/s |
| Axis 2 arm | +95? to -70? | 120?/s | 150?/s |
| Axis 3 arm | +65? to -60? | 120?/s | 150?/s |
| Axis 4 rotation | +200? to -200? | 225?/s | 370?/s |
| Axis 5 bend | +120? to -120? | 250?/s | 330?/s |
| Axis 6 turn | +400? to -400? Max. rev: +200?1 to -200? |
330?/s | 381?/s |
| ?Max. rev: +183 to -183 valid for IRB 4400/L10 | |||
| ?The default working range for axis 6 can be extended by changing parameter values in the software. | |||
| There is a supervision function to prevent overheating in applications with intensive and frequent movements. | |||
“`