| Spesification | |
|---|---|
| Structural Style | Vertical multi-articulated |
| Number of axes | 6 axes |
| Maximum reach | 2107mm |
| Repeatability | ?0.03mm |
| Maximum wrist load | 16 kg |
| IP rating | Body: IP65, Wrist: IP67 |
| Maximum speed : | |
| J1 axis | 190?/s |
| J2 axis | 175?/s |
| J3 axis | 200?/s |
| J4 axis | 400?/s |
| J5 axis | 360?/s |
| J6 axis | 610?/s |
| Maximum motion range : | |
| J1 axis | -170? to +170? |
| J2 axis | -155? to +80? |
| J3 axis | -75? to +160? |
| J4 axis | -180? to +180? |
| J5 axis | -140? to +140? |
| J6 axis | -360? to +360? |
| Allowed wrist load torque : | |
| J4 axis | 25N?m |
| J5 axis | 25N?m |
| J6 axis | 12N?m |
| Allowed wrist load inertia : | |
| J4 axis | 0.78kg?m? |
| J5 axis | 0.78kg?m? |
| J6 axis | 0.3kg?m? |
| User interface : | |
| Wiring | 18?signal,30V,0.5A |
| Air circuit | Air tube: ?8 mm x 1; Pressure resistance: 0.59 Mpa |
| Ambient condition : | |
| Ambient temperature | 0?C to 45?C |
| Ambient humidity (RH) | 5% RH to 75% RH (non-condensing) |
| Maximum temperature gradient | 1.5?C/min |
| Weight | 260kg |
| Input power (average power consumption) | 5kVA(1kW) |
| Matching controller | IRCB501-6FD-INT |
| Mounting method | Floor-mounted |
| Noise level | LAeq?80dB(A) |
| Robot base mounting area | 290mmx280mm(4x?20mm) |
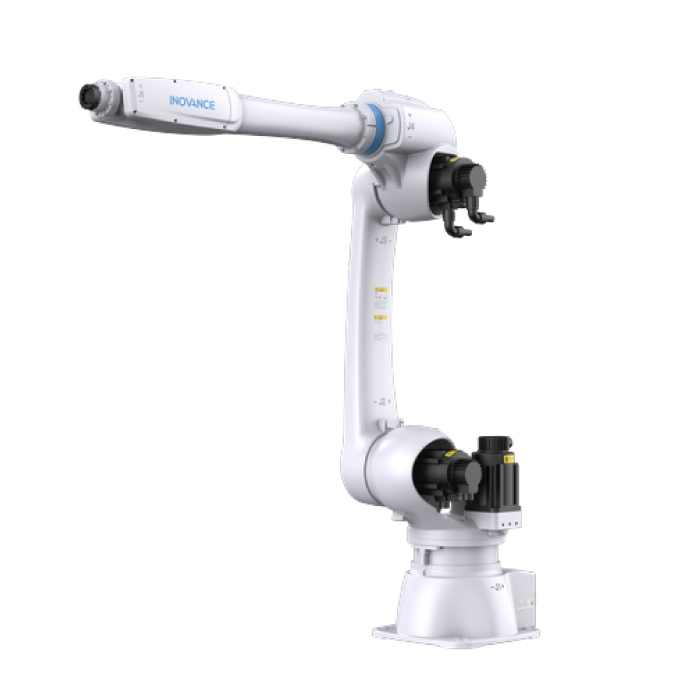
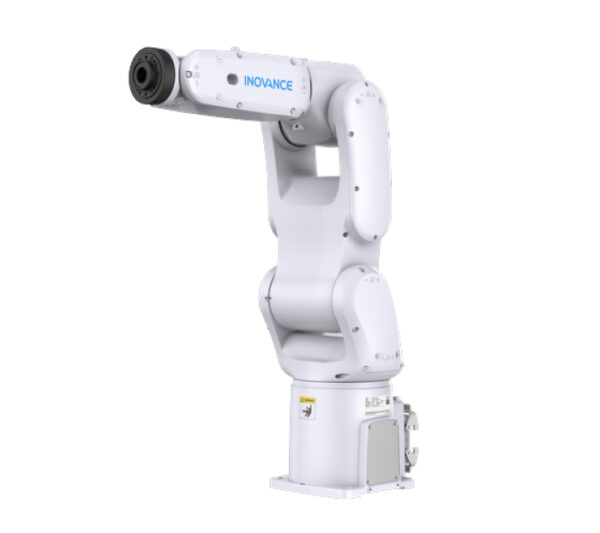
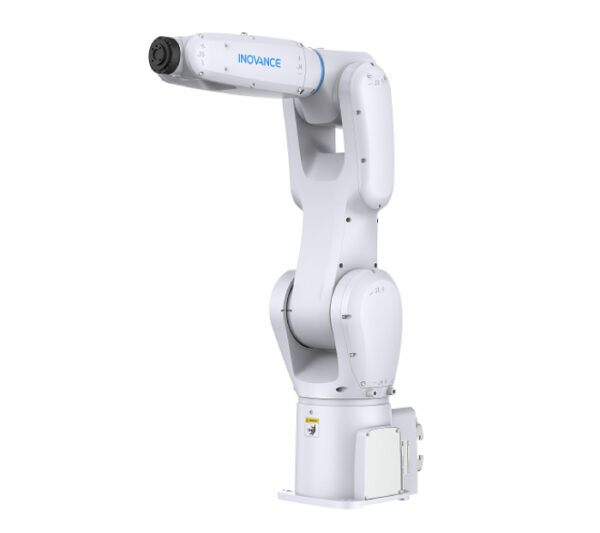
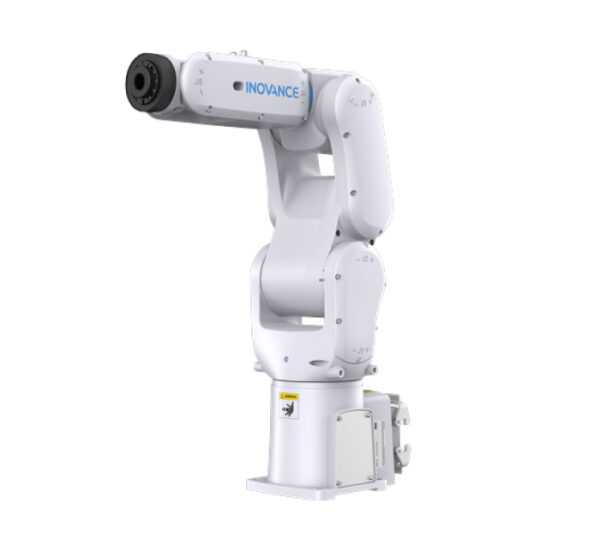
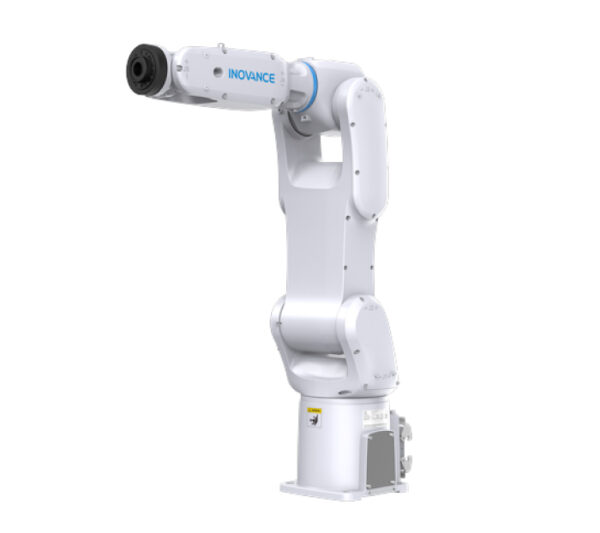
IR-R16-210S-INT
The IR-R16-210S-INT is a 6-axis robot with a maximum payload of 16kg. It features a compact structure, strong load capacity, high repeatability, offering excellent usability and reliability.