| Spesification | |
|---|---|
| Structural Style | Vertical multi-articulated |
| Number of axes | 6 axes |
| Maximum reach | 1101.6 mm |
| Repeatability | ?0.02mm |
| Maximum wrist load | 10 kg |
| IP rating | Standard IP40, optional IP67 |
| Maximum speed : | |
| J1 axis | 240?/s |
| J2 axis | 180?/s |
| J3 axis | 330?/s |
| J4 axis | 450?/s |
| J5 axis | 420?/s |
| J6 axis | 720?/s |
| Maximum motion range : | |
| J1 axis | -170? to +170? |
| J2 axis | -135? to +100? |
| J3 axis | -66? to +210? |
| J4 axis | -190? to +190? |
| J5 axis | -125? to +125? |
| J6 axis | -360? to +360? |
| Allowed wrist load torque : | |
| J4 axis | 18.59 N?m |
| J5 axis | 18.59 N?m |
| J6 axis | 9.8N?m |
| Allowed wrist load inertia : | |
| J4 axis | 0.6 kg?m? |
| J5 axis | 0.6 kg?m? |
| J6 axis | 0.2kg?m? |
| User interface : | |
| Wiring | 12 signal channels, 30 V/0.5 A |
| Air circuit | Air hose: ?4 mm x 4 Withstanding pressure: 0.59 Mpa |
| Ambient condition : | |
| Ambient temperature | 0?C to 45?C |
| Ambient humidity (RH) | Normal: 5% RH to 75% RH (non-condensing) Short-term: 5% RH to 95% RH (within 1 month, non-condensing) |
| Maximum temperature gradient | 1.5?C/min |
| Weight | 48kg |
| Input power (average power consumption) | 3 kVA (0.6 kW) |
| Matching controller | IRCB501-6FD-INT |
| Mounting method | Floor-mounted, ceiling-mounted, wall-mounted |
| Noise level | LAeq?75dB(A) |
| Robot base mounting area | 165 mm x 165 mm (4 x ?11 mm) |
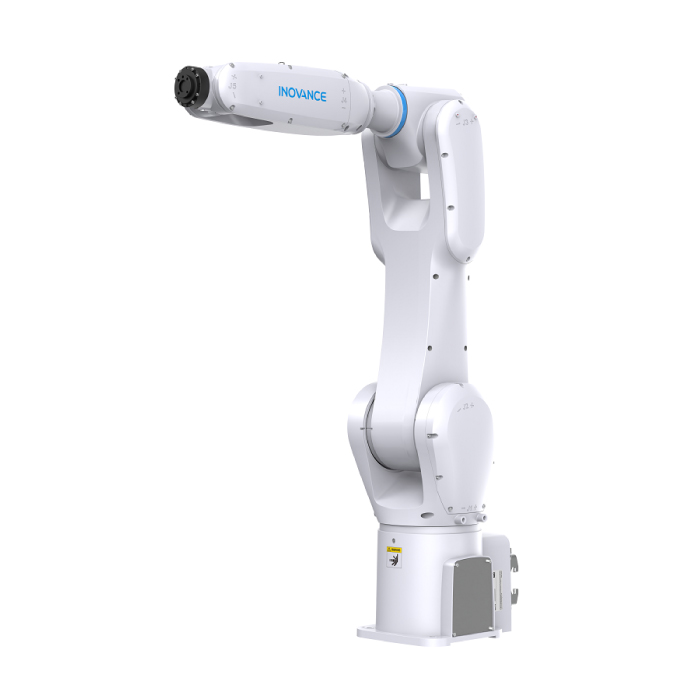
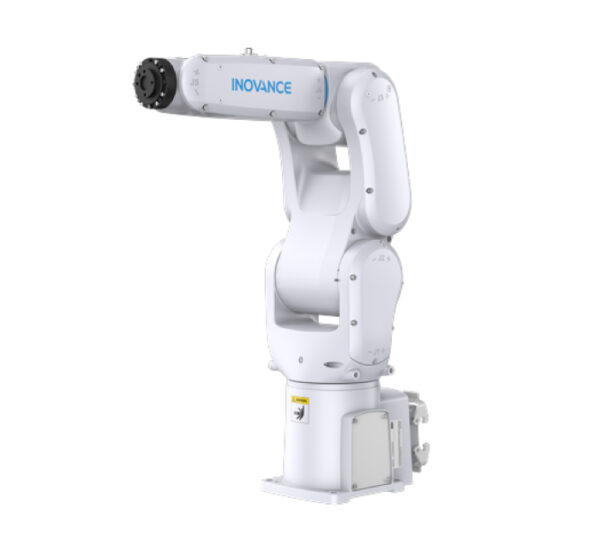
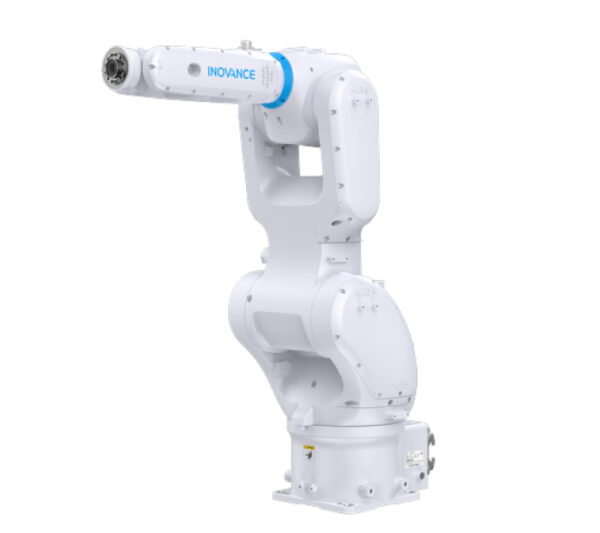
IR-R10-110S-INT
The IR-R11 series 6-axis robots feature a compact structure with industry-leading overall and structural heights. This series is mainly used in assembly and glue application tasks in the 3C, lithium battery, photovoltaics, and display industries.