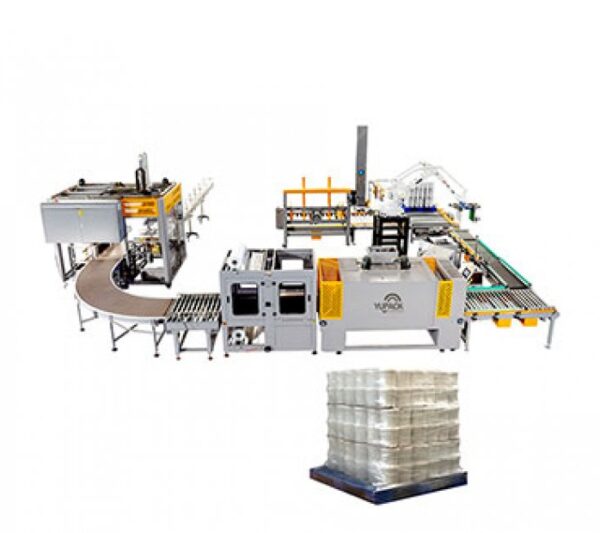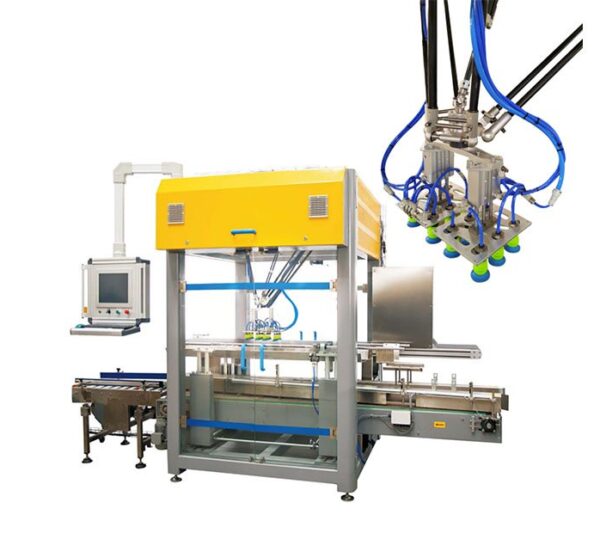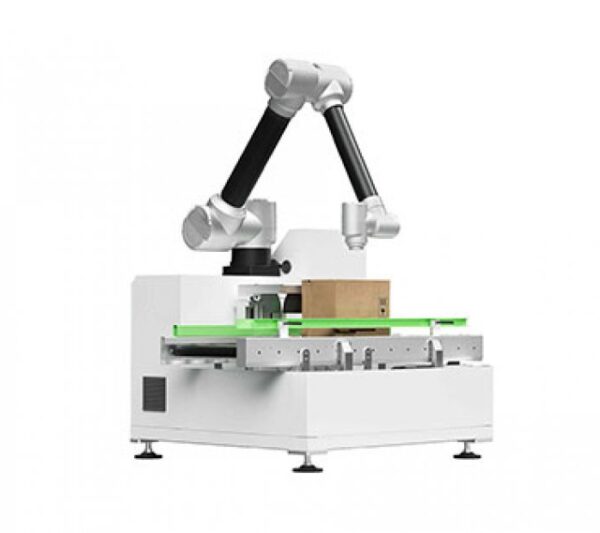
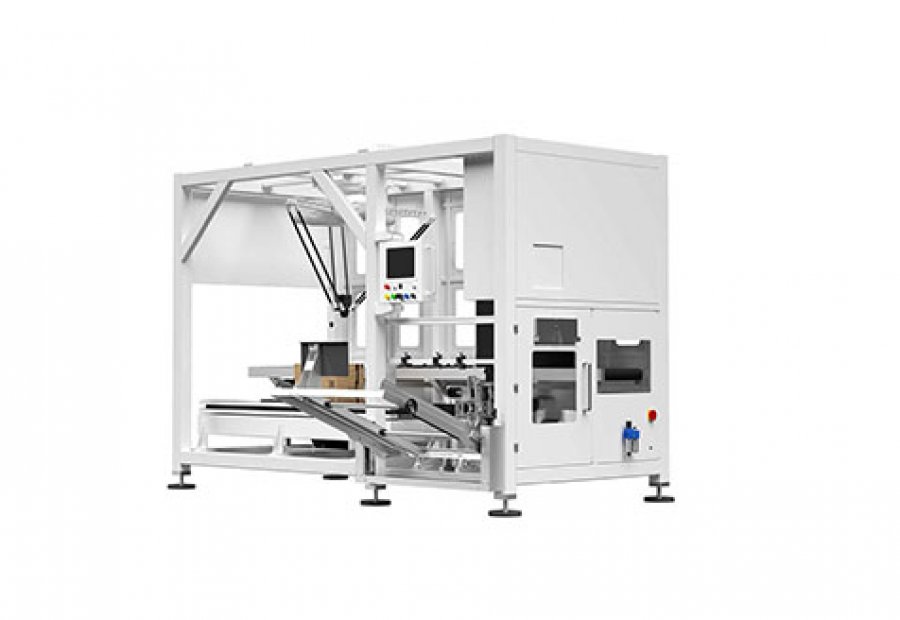
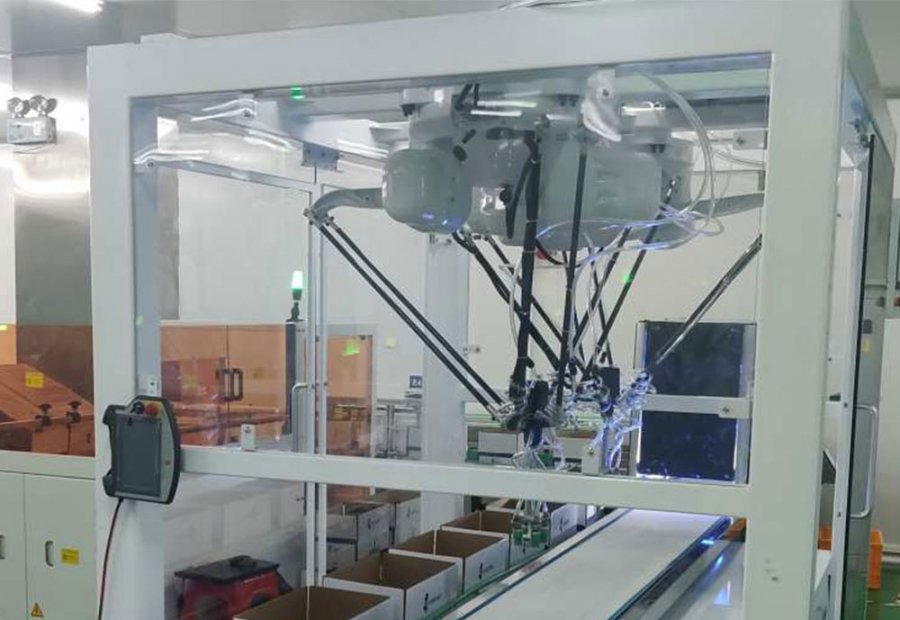
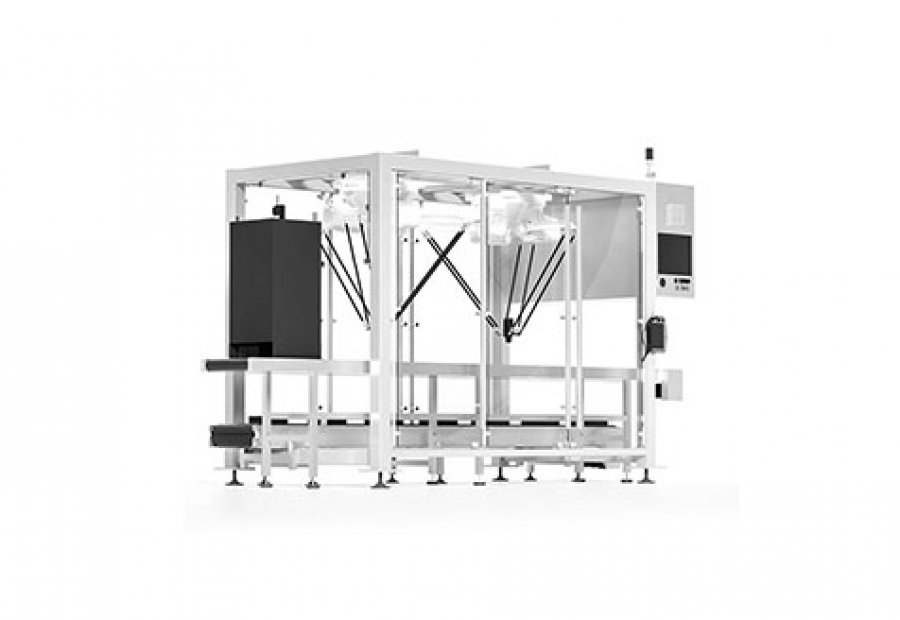
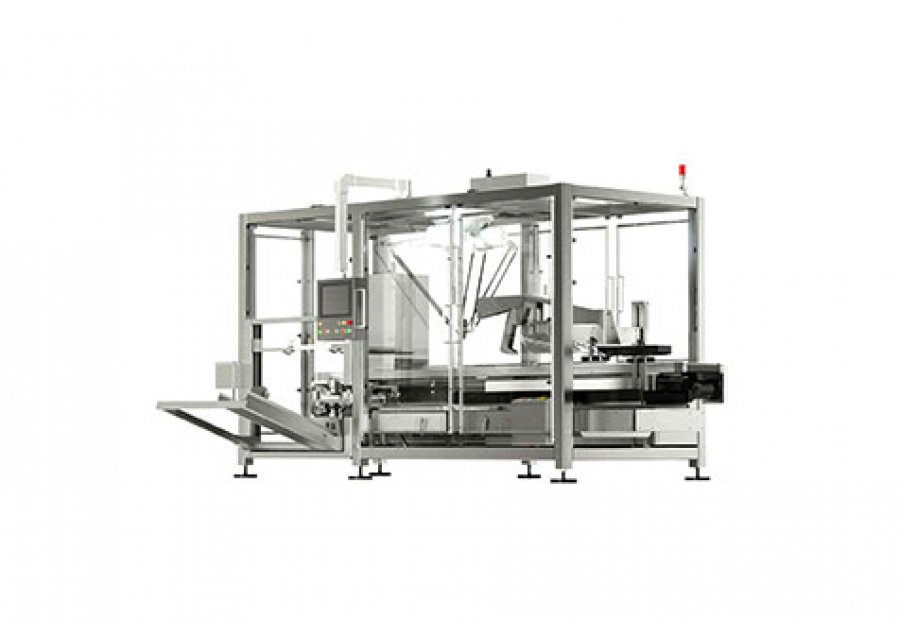
Collaborative Spider Hand Boxing
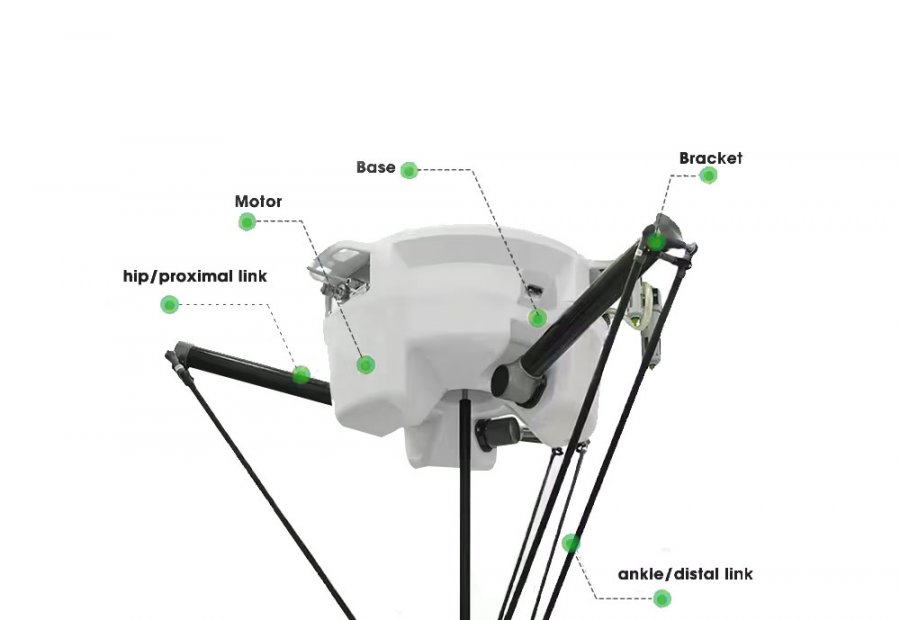
Modular joints: Each joint integrates drive, sensing, and communication units to support rapid reconfiguration.
Collaborative Control Algorithm:
Distributed control: Each unit independently calculates and shares data to achieve overall collaboration.
Dynamic path planning: real-time obstacle avoidance and task assignment (e.g., RRT*, reinforcement learning algorithms).
Force feedback and compliance control: Torque sensors enable safe human-machine interaction or precise operation.