| Spesification | |||
|---|---|---|---|
| Robot version | Reach (m) | Payload (kg) | Armload (kg) |
| IRB 910INV-3/0.35 | 0.35 | 3 | – |
| IRB 910INV-6/0.55 | 0.55 | 6 | – |
| Number of axes | 4 | ||
| Protection | Standard: IP30?. Option IP54 | ||
| Cleanroom | Option: ISO1 | ||
| Mounting | Inverted | ||
| Controller | OmniCore E10, C30, C90XT | ||
| Integrated signal and power supply | 8 signals on outer arm? | ||
| Integrated air supply | 4 air on outer arm (Max. 6 Bar)? | ||
| Integrated ethernet | 1 Gbit/s port? | ||
| ? Ballscrew area: IP20 | |||
| ? Optional | |||
| Performance (according to ISO 9283) | |||
| Robot version | IRB 910INV3/0.35 | IRB 910INV6/0.55 | |
| Pose repeatability (mm) | 0.01 | 0.01 | |
| Linear path repeatability (mm) | 0.06 | 0.05 | |
| Pose stabilizatio time within 0.1 mm of the position | 0.61 | 1.05 | |
| Performance | |||
| Robot version | IRB 910INV3/0.35 | IRB 910INV6/0.55 | |
| 1 kg picking cycle | 0.35 s | 0.40 s | |
| Physical | |||
| Dimensions robot base | 200 x 200 mm | ||
| Weight IRB 910INV-3/0.35 | 19 kg | ||
| Weight IRB 910INV-6/0.55 | 22 kg | ||
| Movement, IRB 910INV-3/0.35 | |||
| Axis movement | Working range | Axis max speed | |
| Axis 1 | -225? to 225? | 672?/s | |
| Axis 2 | -225? to 225? | 748?/s | |
| Axis 3 | -140 mm to 0 mm | 1.1m/s | |
| Axis 4 | -720? to 720? | 3000?/s | |
| Robot version | IRB 910INV-3/0.35 | IRB 910INV-6/0.55 | |
| A (mm) | R350 | R550 | |
| B (mm) | R175 | R275 | |
| C (mm) | 175 | 275 | |
| D (mm) | 140 | 190 | |
| Movement, IRB 910INV-6/0.55 | |||
| Axis movement | Working range | Axis max speed | |
| Axis 1 | -225? to 225? | 420?/s | |
| Axis 2 | -225? to 225? | 780?/s | |
| Axis 3 | -190 mm to 0 mm | 1.1m/s | |
| Axis 4 | -720? to 720? | 3000?/s | |
| Specifications subject to change without notice. | |||
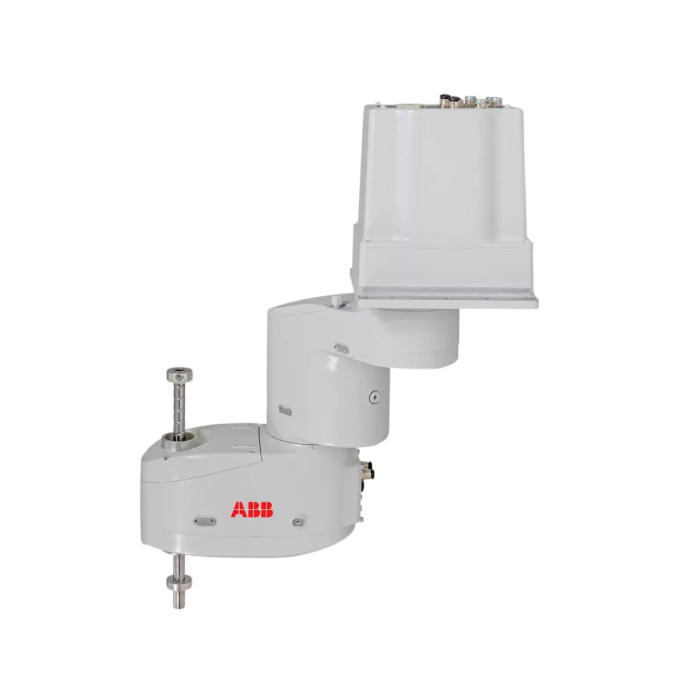
IRB-910INV
Ceiling-mounted SCARA increases the working area
ABB?s new ceiling-mounted IRB 910INV robot is designed to increase the space efficiency and flexibility of each cell and support the performance of complex tasks even in confined spaces. By mounting the IRB 910INV on the ceiling, manufacturers can increase the space efficiency and flexibility of each cell and do more complex tasks even in confined spaces. Moreover, the IRB 910INV robot can collaborate with other robots and machines, substantially boosting productivity.
Powered by an ABB OmniCore controller, the IRB 910INV robot offers the best-in-class motion control for repeatable point-to-point accuracy during pickand-place, assembly, and testing applications. This includes electronics small parts assembly tasks such as screw driving, component inserting or mounting, and automated quality control inspections. IP54 and Cleanroom ISO 1 are available options. IRB 910INV is ISO 14644-1 certified for use in cleanroom applications in, for example, the semiconductor industry.