| Spesification | |
|---|---|
| Reach | |
| Arm 1+Arm 2 | 1200 mm |
| Arm 1 | 750 mm |
| Arm 2 | 450 mm |
| Maximum speed | |
| J1+J2 | 9400 mm/s |
| J3 | 1200 mm/s |
| J4 | 705?/s |
| Repeat accuracy | |
| J1+J2 | ?0.08 mm |
| J3 | ?0.01 mm |
| J4 | ?0.01? |
| Payload (load capacity) | |
| Nominal | 20 kg |
| Maximum | 35 kg |
| Allowable load inertia of J4 | |
| Nominal | 0.6 kg?m? |
| Allowable load inertia of J5 | |
| Maximum | 1.2 kg?m? |
| Mounting hole | 200 mm ? 200 mm (4 ? ?16 mm) |
| Body weight (excluding cables) | 80.5 kg |
| Press-in force of J3 | 250 N |
| User wiring | |
| Wiring | 25x signal, 30 V, 0.5 A |
| Network port | CAT5E |
| User air circuit | Air tube: ?6 mm ? 2, ?8 mm ? 2; Pressure resistance: 0.59 Mpa |
| Ambient conditions | |
| Ambient temperature | 5?C to 40?C |
| Ambient humidity | 10% to 80% |
| Noise level | LAeq ? 80 dB(A) |
| Maximum motion range | |
| J1 | ?139? |
| J2 | ?151? |
| J3 | 420 mm |
| J4 | ?360? |
| Cycle time | 0.42s |
| Input power (average power consumption) | 2 kVA (0.3 kW) |
| Applicable control cabinet (standard) | IRCB501-4ED-INT |
| Installation method | Tabletop |
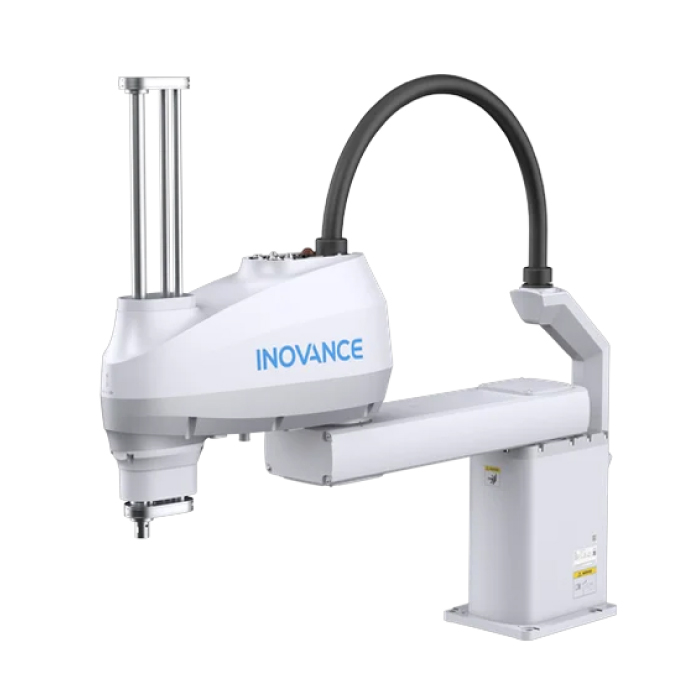
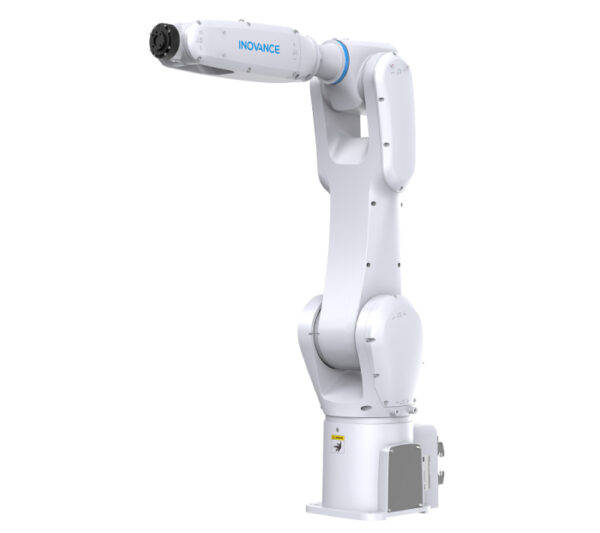
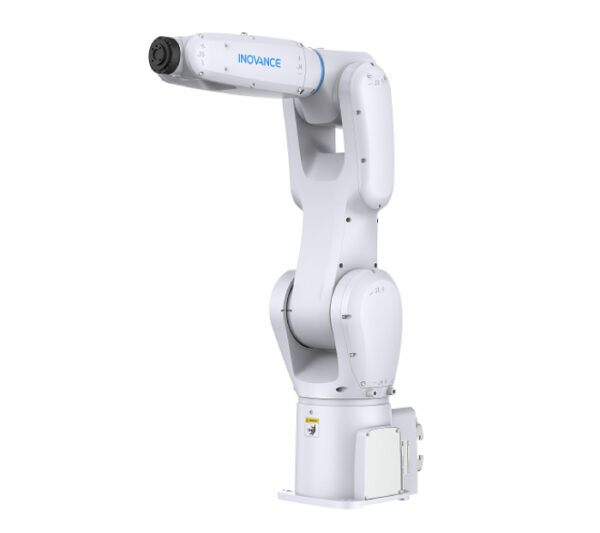
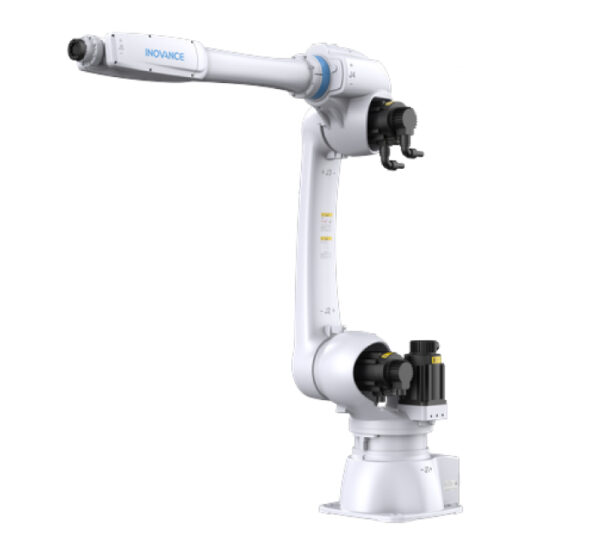
IR-S35-120Z42S-INT
The IR-S35 series robot is designed for application in lithium battery industry, with a maximum payload of 35 kg and a Z-axis stroke of 420 mm (350 mm for cleanroom model). The J4 axis of the robot is driven by a harmonic reducer, and the J3 axis is equipped with two plain shafts to enhance the rigidity when moving under the operating conditions involving high payload, long stroke and large eccentric loads. The robot offers high inertia, strong rigidity and high precision.