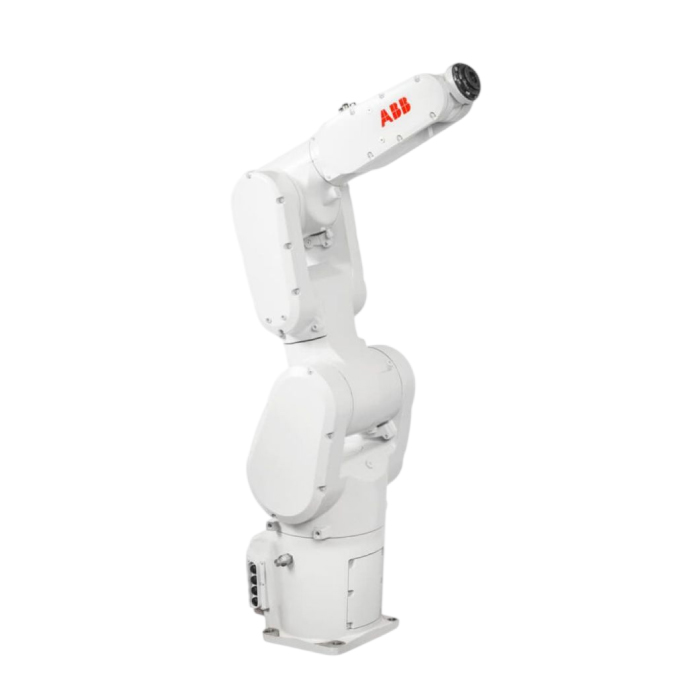
| Spesification | ||||
|---|---|---|---|---|
| Robot version | Reach (m) | Payload (kg) | Armload (kg) | |
| IRB 1300-11/0.9 | 900 | 11 | 1 | |
| IRB 1300-10/1.15 | 1150 | 10 | 0.5 | |
| IRB 1300-7/1.4 | 1400 | 7 | 0.5 | |
| IRB 1300-12/1.4 | 1400 | 12 | 0.5 | |
| Number of axes | 6 | |||
| Protection | Standard IP40, Option: IP67, Foundry Plus 2 | |||
| Cleanroom | Option ISO 4 | |||
| Mounting | Any angle? | |||
| Controller | OmniCore | |||
| Integrated signal and power supply | Up to 24 Signals (C1+C2+C3) on wrist (optional) | |||
| Integrated air supply | 6 x 4 air on wrist (Max. 6 Bar)? | |||
| Integrated ethernet | One 1000 Base-T ethernet port? | |||
| ? There are some reachable space limitation when the payload/pose is tough. ? Optional. |
||||
| Performance (according to ISO 9283) | ||||
| Robot version | IRB 1300-11/0.9 | IRB 1300-10/1.15 | IRB 1300-7/1.4 | IRB 1300-12/1.4 |
| Position repeatability RP (mm) | 0.02 | 0.023 | 0.03 | 0.05 |
| Pose stabilization time, PSt (s) within 0.1 mm of the position | 0.28 | 0.27 | 0.38 | 0.56 |
| Path repeatability RT (mm) | 0.08 | 0.04 | 0.07 | 0.04 |
| Cycle time? | ||||
| 1 kg picking cycle 25* 300 * 25mm | 0.37s | 0.43s | 0.43s | 0.38s |
| 2 kg picking cycle 25* 300 * 25mm | 0.39s | |||
| Physical | ||||
| Dimensions robot base (mm) | 220×220 | |||
| Weight (kg) | 75 | 77 | 79 | 79 |
| ? Given motion pattern with optimized set up. | ||||
| Movement, IRB 1300-11/0.9 | ||||
| Axis movement | Working range | Axis max speed? | ||
| Axis 1 rotation | +180? to -180? | 280?/s | ||
| Axis 2 arm | +130? to -100? | 228?/s | ||
| Axis 3 arm | +65? to -210? | 330?/s | ||
| Axis 4 wrist | +230? to -230? | 500?/s | ||
| Axis 5 bend | +130? to -130? | 415?/s | ||
| Axis 6 turn | +400? to -400? | 720?/s | ||
| Movement, IRB 1300-10/1.15 | ||||
| Axis movement | Working range | Axis max speed? | ||
| Axis 1 rotation | +180? to -180? | 280?/s | ||
| Axis 2 arm | +155? to -95? | 228?/s | ||
| Axis 3 arm | +65? to -210? | 336?/s | ||
| Axis 4 wrist | +230? to -230? | 500?/s | ||
| Axis 5 bend | +130? to -130? | 415?/s | ||
| Axis 6 turn | +400? to -400? | 720?/s | ||
| Movement, IRB 1300-7/1.4 | ||||
| Axis movement | Working range | Axis max speed? | ||
| Axis 1 rotation | +180? to -180? | 255?/s | ||
| Axis 2 arm | +155? to -95? | 180?/s | ||
| Axis 3 arm | +69? to -210? | 247?/s | ||
| Axis 4 wrist | +230? to -230? | 500?/s | ||
| Axis 5 bend | +130? to -130? | 415?/s | ||
| Axis 6 turn | +400? to -400? | 720?/s | ||
| Movement, IRB 1300-12/1.4 | ||||
| Axis movement | Working range | Axis max speed? | ||
| Axis 1 rotation | +180? to -180? | 230?/s | ||
| Axis 2 arm | +155? to -95? | 116?/s | ||
| Axis 3 arm | +69? to -210? | 138?/s | ||
| Axis 4 wrist | +230? to -230? | 500?/s | ||
| Axis 5 bend | +130? to -130? | 415?/s | ||
| Axis 6 turn | +400? to -400? | 720?/s | ||
| ?The Axis max speed varies subject to controller. Please check detail information from Product Specification. Specifications subject to change without notice. |
||||
“`